ESO ELT AXES CONTROL
High-precision telescope axes control system
2027
Project specifications
Main Scope
High-precision telescope axes control system
Developed by
Microgate, subcontractor of Cimolai SpA
Project completion
2027
Control focus
telescope tracking and pointing accuracy
Control architecture
real-time motion control system
Operational environment
large-scale telescope structure
Current phase
prototype testing, system integration
Application field
Telescope and Radio telescopes main axes control
First light
the telescope axes will be fully operative in 2027

Cerro Armazones, Chile

ESO
ESO ELT AXES CONTROL
High-precision telescope axes control system
Status:
Control system design completed, prototype testing in progress
Lorem ipsum dolor sit amet, consectetur adipiscing elit, sed do eiusmod tempor incididunt ut labore et dolore magna aliqua. Lorem ipsum dolor sit amet, consectetur adipiscing elit, sed do eiusmod tempor incididunt ut labore et dolore magna aliqua.
Description
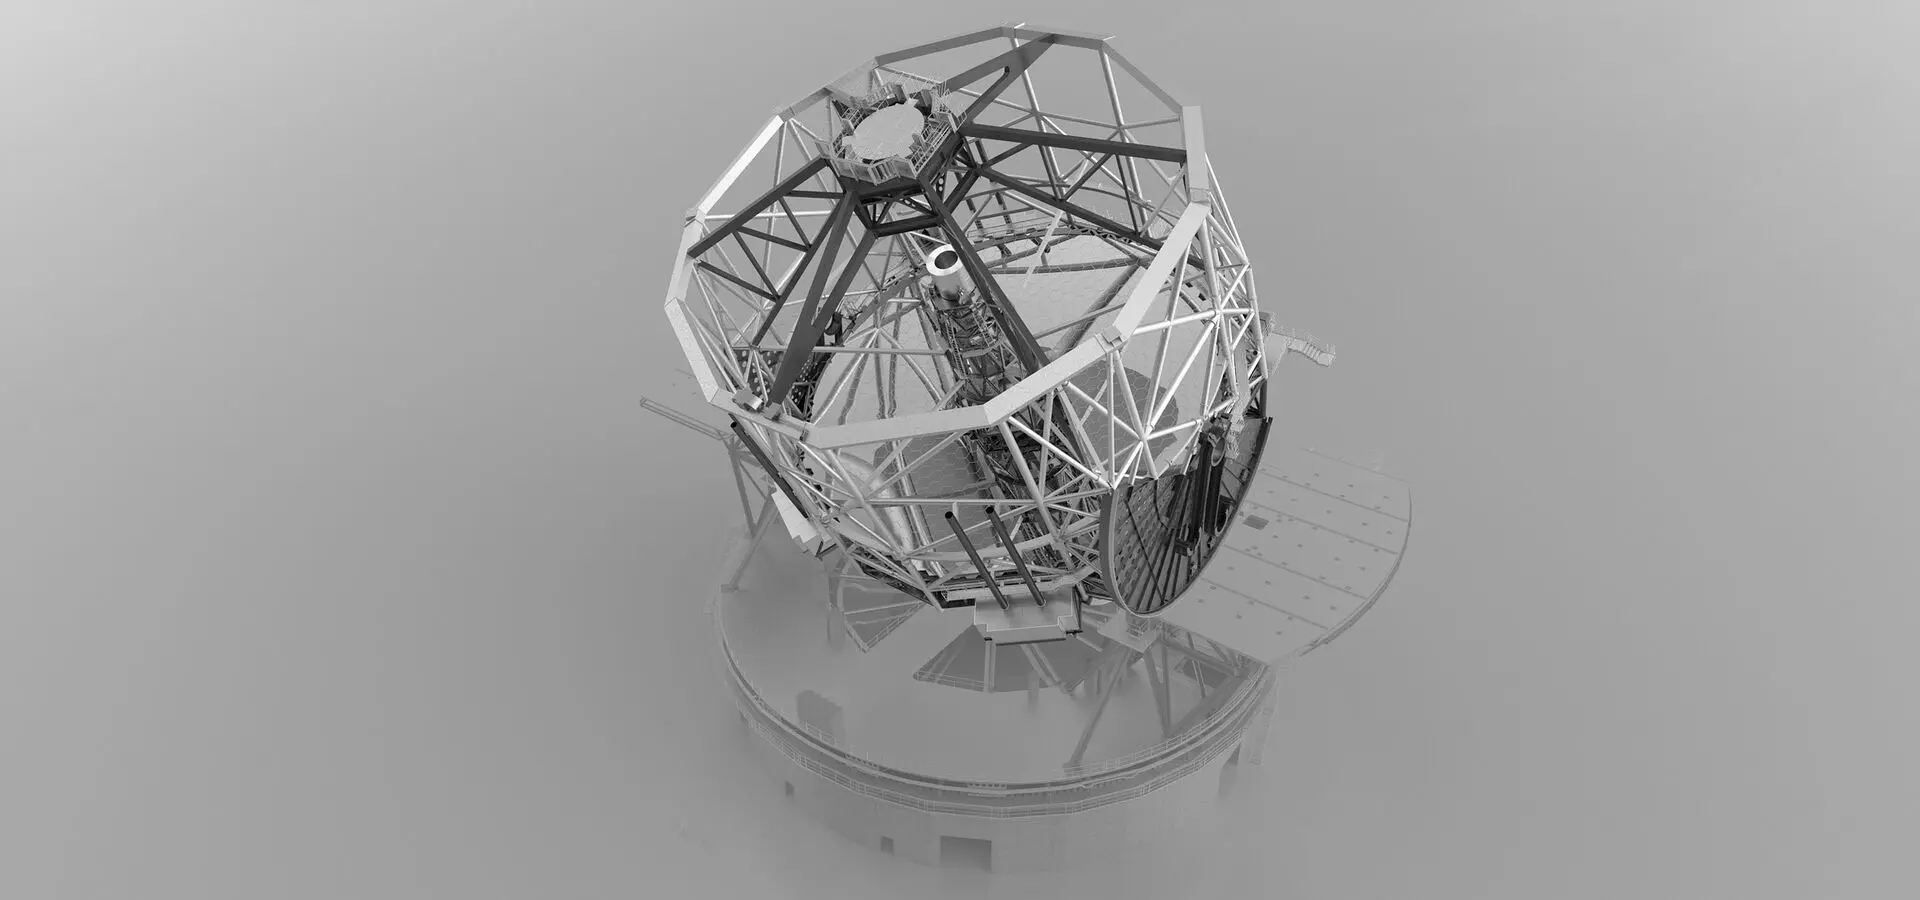
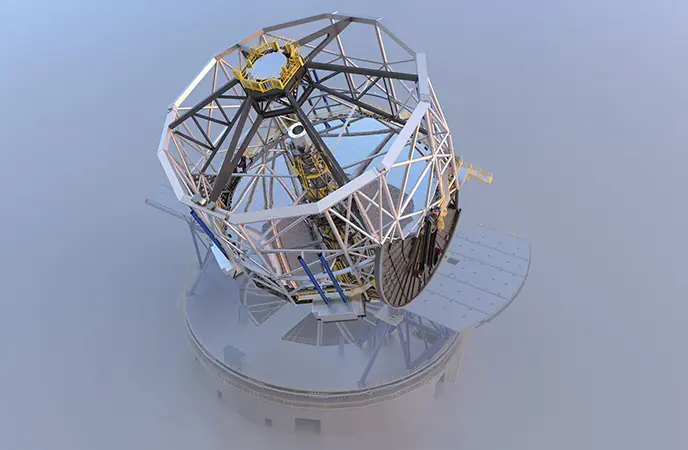
The ESO ELT Axes Control project focuses on the development of the high-precision axis control system for the Extremely Large Telescope (ELT). Developed in cooperation with Cimolai SpA. and Danieli Automation SpA, the system is designed to guarantee exceptional stability and tracking accuracy while managing the movement of the telescope’s main axes massive mechanical structure under varying operational and environmental conditions. The telescope axes, with a moving mass in excess of 4000 tons, are moved by large direct-drive linear motors and the axes float on thin oil film, so to minimize any friction to guarantee the maximum precision The control architecture plays a critical role in preserving the pointing precision required to achieve the ELT’s scientific objectives, enabling smooth and accurate telescope motion during astronomical observations.
microgate responsibilities
Microgate is responsible for the development of the core control and trajectory management system for the ELT main axes. Our scope focuses on ensuring high-precision tracking and pointing performance during observation activities, interfacing dedicated real-time control systems with the automation infrastructure provided by Cimolai and Danieli Automation.The project includes the dynamic simulation of the controlled structure, enabling design and numerical optimization of advanced motion control algorithms, their deployment on a real-time computer that will perform the control tasks, on-site performance optimization and testing until final commissioning. All these aims aimed at guaranteeing stable and reliable telescope operations under dynamic load conditions.
We are currently testing a large axis prototype aimed to reproduce, on a smaller scale, most of the control peculiarities of the actual telescope axes.